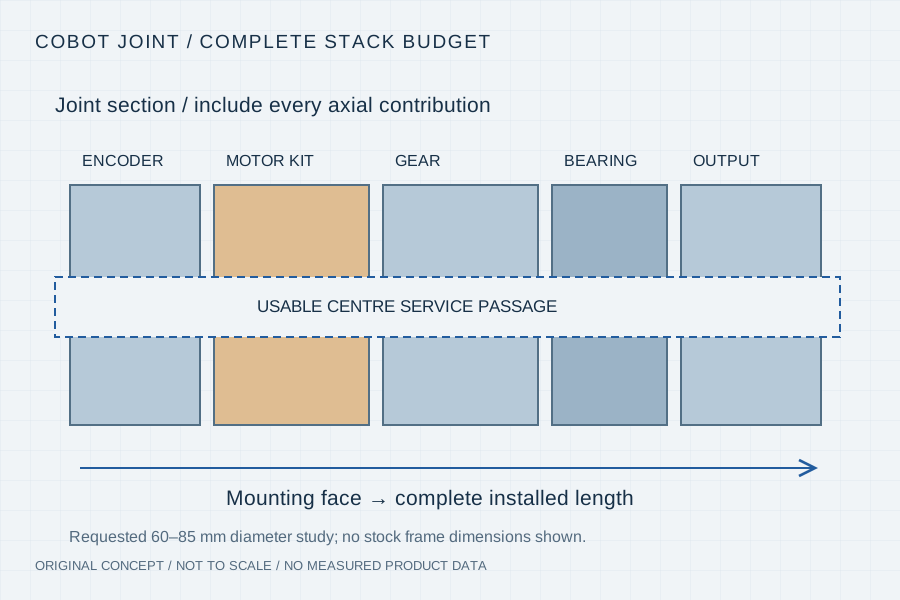
48V JOINT / MOTOR-GEAR-BEARING INTERFACE
48V Pancake Motors for Compact Cobot Joints ↗
Plan a 48V cobot joint around motor depth, gear interfaces and cooling. Send your gearbox drawing, clear-bore needs and torque-speed cycle for review.
APPLICATION GUIDES / INSTALLED CONSTRAINTS
Choose the decision your assembly needs to resolve: joint stack, moving service passage, scan motion or wheel duty. Each guide helps you prepare the installation constraints and acceptance evidence for a project-specific review.
48V JOINT / MOTOR-GEAR-BEARING INTERFACE
Plan a 48V cobot joint around motor depth, gear interfaces and cooling. Send your gearbox drawing, clear-bore needs and torque-speed cycle for review.
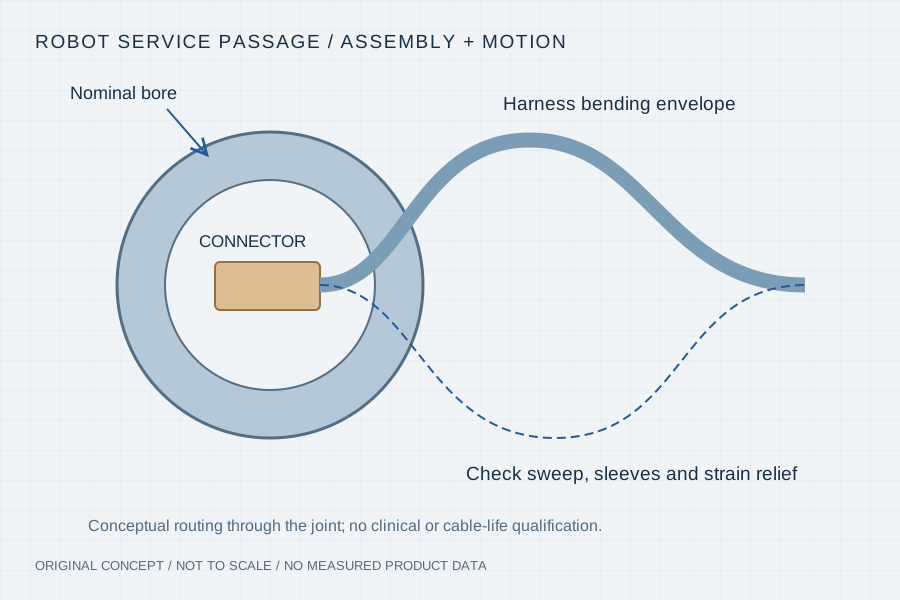
SURGICAL ROBOT SUBSYSTEM / MOVING SERVICE PASSAGE
Define a surgical robot motor bore around connectors, moving cables and joint travel. Send routing drawings, exposure boundaries and motion duty for review.
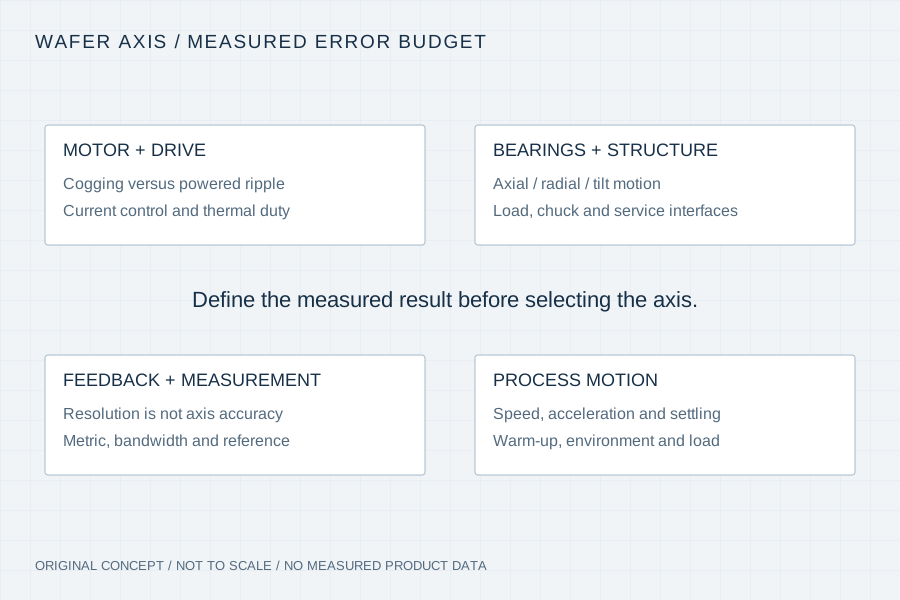
SEMICONDUCTOR AXIS / SCAN AND SETTLING CONDITIONS
Define wafer-stage motion with scan speed, settling, load and measurement conditions. Send your axis envelope and error budget for a slotless motor review.
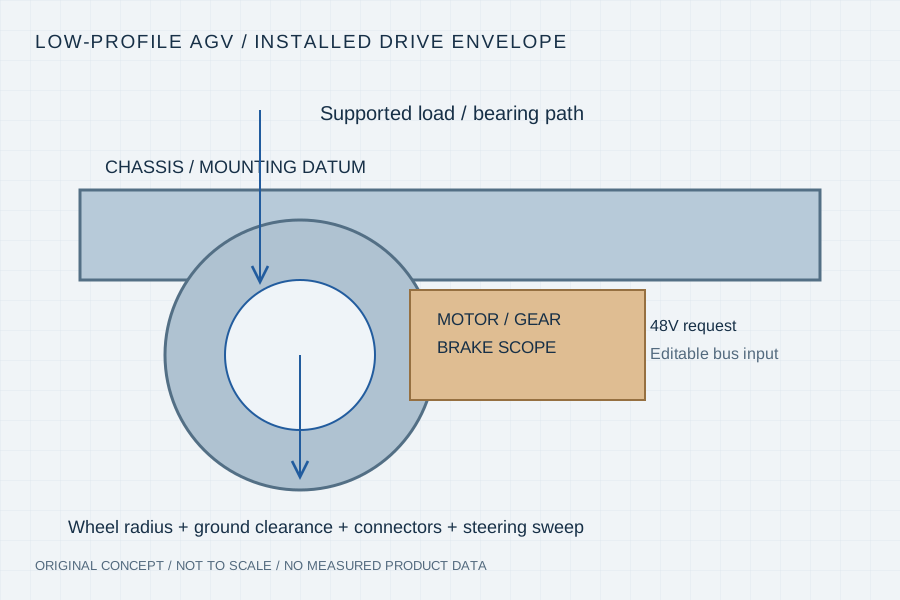
48V MOBILE BASE / WHEEL LOAD AND INSTALLED HEIGHT
Plan a low-profile 48V AGV drive around wheel load, slope, starts and braking. Send the full installed envelope, battery range and duty cycle for review.
The guides collect requested dimensions, machine duty and document availability. They do not return a qualified model or replace an assembled-system test. If your project is still exploratory, use the broader application overview or define a motor envelope first.