CLOSED-LOOP MOTION / AXIS RESPONSIBILITIES
Pancake servo motors for complete axes.
Start with the positioning task and the complete axis boundary. Define who supplies the flat motor, drive, feedback, bearings, transmission and any brake before comparing a motor-only envelope.
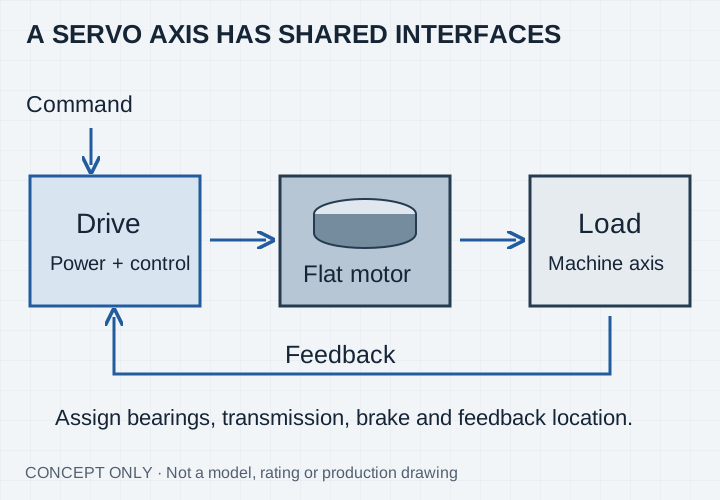
Assign the motor, drive, feedback and brake boundary
Servo describes controlled behavior, not one motor construction. A motor plus an encoder is not yet an agreed and accepted positioning axis.
| Axis element | Assign in the supply scope | Evidence to agree |
|---|---|---|
| Pancake motor | Winding, rotor, housing/kit, torque-speed duty and thermal interface | Drawing revision and supported rating conditions. |
| Drive and power system | Control modes, current limits, command interface, commissioning and regeneration | Motor parameters, drive settings and loaded operation. |
| Position feedback | Sensor, location, signal/protocol, homing and commutation relationship | Wiring, calibration/offset and measured positioning behavior. |
| Bearings and transmission | Load support, coupling/gearbox, stiffness and mechanical interfaces | Installed stack, alignment and load-side acceptance measurements. |
| Brake / power-loss behavior | Required holding/stopping function, command sequence and machine owner | Project-specific operating and power-loss test plan. |
Engineering reference: Kollmorgen: servomotor function and position feedback. This establishes general context, not a PancakeMotors rating or supplied component.
Describe the motion error at the load, not only encoder counts
Provide the moved inertia or load, acceleration/deceleration cycle, transmission ratio and requested position/speed behavior. Keep motor-side and load-side quantities explicitly labelled.
| Operating question | Input to the review | Acceptance condition |
|---|---|---|
| Index to a position | Move angle, move time, load and dwell | Position-error window and settling time under the stated load. |
| Track a scan | Velocity/acceleration profile, feedback location and controller bandwidth | Measured following error or speed variation over the relevant band. |
| Hold against a load | External torque, dwell and thermal path | Position drift and temperature at the agreed operating condition. |
| Start after power-up | Homing/absolute reference and commutation strategy | Permitted travel, reference acquisition and repeatability. |
| Stop or lose power | Stored/load energy and required machine behavior | Allocated drive/brake/transmission tests and responsible owner. |
Engineering reference: Renishaw: accuracy, resolution and repeatability definitions. This establishes general context, not a PancakeMotors rating or supplied component.
Put feedback, coupling and cable space into the axis depth
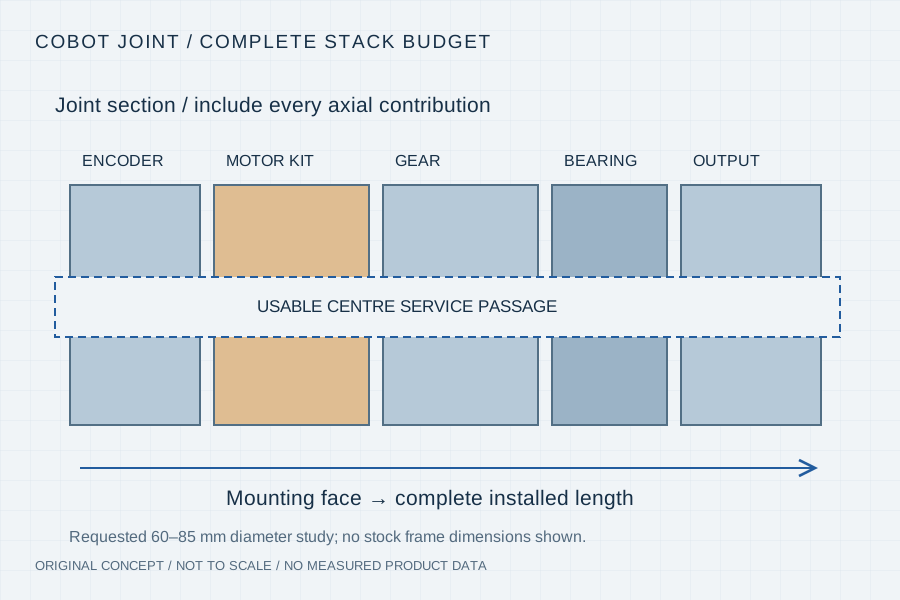
A feedback device belongs to both the control definition and the physical envelope. Include its mounting, reference alignment, connector and cable sweep in the installed drawing.
If feedback is motor-side, evaluate how the transmission and structural compliance affect the quantity controlled at the load. If the measurement is load-side, define that sensor interface and commissioning responsibility explicitly.
Provide the exact feedback protocol and drive variant rather than assuming an incremental, absolute, resolver or Hall interface is interchangeable. The supported combination needs confirmation from the selected drive documentation.
Engineering reference: Kollmorgen: servo motor, feedback and drive as a system. This establishes general context, not a PancakeMotors rating or supplied component.
Separate a holding brake from the requested stopping duty
Specify the load, stopping sequence, release/engagement timing and required behavior if power is lost. A static holding function does not establish repeated dynamic-stop capability.
Kollmorgen documents standstill-brake boundaries and additional installed motor length for its holding-brake options. Treat those as a reminder to review the chosen component and machine arrangement; they are not specifications for a PancakeMotors brake.
State who owns machine-level protection and acceptance. This inquiry allocates review work; it does not certify a machine, a suspended-load arrangement or a safety function.
Engineering reference: Kollmorgen: holding-brake use and installation boundaries. This establishes general context, not a PancakeMotors rating or supplied component.
Release an axis against a revision and a measured motion task
Agree the supplied elements, retained elements and commissioning work in writing. Link each requested result to the same machine drawing, load case, drive configuration and measurement method.
A frameless motor, a housed BLDC motor or an industrial brushed motor can form part of different closed-loop systems. Select the motor construction through the mechanical, electrical and service requirements; do not treat servo as a synonym for brushless, geared or legacy ServoDisc.
No axis accuracy, stock actuator, matched drive/brake kit or rated model is published here. Send the axis task to establish a review scope, then agree prototype deliverables and system acceptance before procurement.
Your inputs / an actionable review
Prepare the pancake servo axis integration brief.
Enter known constraints or “Need advice”. Mark documents you can provide; this records availability, not file inspection or engineering approval. No document is required to start a discussion.
4 document topics to discuss. Selected documents have not been uploaded or reviewed.
Carry This Brief into the Web Inquiry ↗Your email, already structured
Prepare your engineering brief
Use the same brief in your email client or copy it with our address. Add photos or drawings as email attachments when available.
Downloads contain your entered details and file links, including contact details when provided. Keep or share them according to your project’s confidentiality requirements. Saving a draft does not send it to us. The JSON restores the inquiry form; it is not a CAD attachment.
Read or select the complete technical brief
Your inputs remain in this page until you send the web form. If your email app omits a long message, copy the complete brief above.
Servo axis scope, feedback and acceptance questions
Is a pancake servo motor a specific electromagnetic topology?
No. Servo describes the controlled motion task. Motor construction, feedback and drive are separate choices. Specify the positioning or speed requirement and the supplied axis elements together.
Can a brushless pancake motor become part of a servo axis?
Yes, if the motor, compatible drive, feedback and mechanical integration meet the required task. A brushless label or an encoder option does not establish the complete axis performance.
Is the encoder resolution the promised axis accuracy?
No accuracy promise follows from the encoder label alone. Define the measured error at the relevant shaft or load, with load, transmission, temperature, reference and measurement conditions. The project acceptance test must demonstrate the requested result.
Does a brake option provide the required emergency stopping behavior?
Do not infer it from the presence of a brake. Specify holding, stopping and power-loss requirements separately, then validate the selected hardware and control sequence with the machine owner. No safety function is certified by this review.
What is the difference from replacing a legacy ServoDisc motor?
An existing-machine assessment starts with the full original model, drive, feedback and retained interfaces. Use the legacy review route for that task. This page scopes a complete low-profile controlled axis and does not assert drop-in interchangeability.
What can I send before all axis components are chosen?
Send the available envelope, load and motion profile, required error/settling criteria and a responsibility list with unknown items marked. The editable draft can be shared internally before you complete and send the inquiry.
Compare the next motor or machine integration decision.
Engineering scope reviewed 24 October 2026. Operator: Magatom Dynamics. Requested configuration and evidence are reviewed before a model, supply scope or commercial commitment is confirmed.